Q.A uniform metallic rod rotates about its perpendicular bisector with constant angular speed. If it is heated uniformly to raise its temperature slightly
Concept understanding — Rotational Dynamics
Rotational Dynamics: The Physics of Spinning Things
Imagine you're trying to open a heavy door. You push near the hinge — it barely moves. Push near the handle — it swings open easily. Same force, different result. That's the first clue: rotation isn't just about how much you push, but where and in what direction.
Now think about a spinning bicycle wheel. Why is it so hard to tilt it sideways when it's spinning fast? And why does a figure skater spin faster when she pulls her arms in? These are the questions rotational dynamics answers.
The Core Idea
Rotational dynamics is the study of why things rotate and how their rotation changes. It's the spinning-world equivalent of Newton's laws for straight-line motion.
In linear motion, you have:
- Force (F) causes acceleration (a)
- Mass (m) resists acceleration
In rotational motion, you have:
- Torque (τ) causes angular acceleration (α)
- Moment of inertia (I) resists angular acceleration
The master equation is:
τnet=Iα
This is the rotational version of F=ma. Every term has a direct parallel.
Breaking It Down
Torque — The Rotational "Push"
Torque isn't just force — it's force multiplied by the distance from the pivot point (the lever arm). That's why the door handle works better than the hinge.
τ=rFsinθ
Where r is the distance from the axis, F is the force, and θ is the angle between them. Maximum torque happens when you push perpendicular to the lever arm (θ=90∘).
Think of torque as "twisting effectiveness." A wrench works because the handle gives you a long lever arm. A short wrench needs more force to do the same job.
Moment of Inertia — The Rotational "Mass"
Mass resists linear acceleration. Moment of inertia resists angular acceleration. But unlike mass, moment of inertia depends on how the mass is distributed relative to the axis of rotation.
For a point mass m at distance r from the axis:
I=mr2
For extended objects, you sum (or integrate) over all mass elements:
I=∑miri2
| Object | Axis | Moment of Inertia |
|--------|------|-------------------|
| Thin hoop | Through center, perpendicular to plane | MR2 |
| Solid disk | Through center, perpendicular to plane | 21MR2 |
| Solid sphere | Through center | 52MR2 |
| Thin rod | Through center, perpendicular to rod | 121ML2 |
Notice: a hoop has more moment of inertia than a disk of the same mass and radius because its mass is farther from the axis. That's why a hoop is harder to start spinning.
Angular Acceleration — How Fast Rotation Changes
Just as acceleration is the rate of change of velocity, angular acceleration α is the rate of change of angular velocity ω:
α=dtdω
And angular velocity is the rate of change of angular displacement θ:
ω=dtdθ
The Complete Picture: Rotational Analogues
| Linear Quantity | Rotational Analogue |
|---|---|
| Displacement x | Angular displacement θ |
| Velocity v | Angular velocity ω |
| Acceleration a | Angular acceleration α |
| Mass m | Moment of inertia I |
| Force F | Torque τ |
| Newton's 2nd law: F=ma | τ=Iα |
| Kinetic energy: 21mv2 | 21Iω2 |
| Momentum: p=mv | Angular momentum: L=Iω |
The Key Insight: Conservation of Angular Momentum
This is where rotational dynamics gets beautiful. Just as linear momentum is conserved when no external force acts, angular momentum is conserved when no external torque acts:
L=Iω=constant
That's why the figure skater spins faster when she pulls her arms in. Her moment of inertia I decreases, so her angular velocity ω must increase to keep L constant. No external torque — just redistribution of mass.
A common mistake: thinking that angular momentum is always conserved. It's conserved only when the net external torque is zero. If you apply a torque (like friction on a spinning wheel), angular momentum changes.
Putting It All Together
When you encounter a rotational dynamics problem:
- Identify the axis of rotation — everything depends on this
- Find the net torque — sum all torques (with sign conventions)
- Determine the moment of inertia — use the right formula for the shape and axis
- Apply τnet=Iα — this gives you angular acceleration
- Use kinematic equations (if needed) — they're the same as linear ones, just with θ, ω, α
The beauty of rotational dynamics is that once you understand the parallels, you already know most of the physics. The hard part is just the geometry — figuring out lever arms and mass distributions.
If you landed here looking for "Rotational Dynamics formula" or "Rotational Dynamics numericals class 11", it helps to know that Rotational Dynamics is a core, NCERT-aligned topic from the System of Particles and Rotational Motion portion of the Class 11 Physics curriculum, and it is tested regularly in CBSE board exams as well as in JEE Main and NEET. Revisiting the NCERT Physics textbook exercises for this chapter alongside the walkthrough above is a solid way to convert this into exam-ready practice.
Concept: Rotational Dynamics — conservation of angular momentum when no external torque acts.
Reasoning:
- The rod rotates freely about its perpendicular bisector with constant angular speed. No external torque acts on the system, so angular momentum L=Iω is conserved.
- On uniform heating, the rod expands. Its moment of inertia about the perpendicular bisector increases because mass moves farther from the axis: I∝(length)2 for a rod.
- Since L is constant, an increase in I forces a decrease in ω (angular speed).
Option (D) is wrong — speed does not increase because moment of inertia increases; it decreases.
The correct option is (B): its speed of rotation decreases.
Heating the rod increases its length, which increases its moment of inertia. Since no external torque acts, angular momentum is conserved, so angular speed must decrease.
The Concept: Rotational Dynamics and Thermal Expansion
When a body rotates freely with no external torque, its angular momentum L=Iω stays constant. Here I is the moment of inertia and ω the angular speed. If the body’s shape changes — as it does when heated — I changes, and ω must adjust to keep L unchanged.
The rod is uniform and rotates about its perpendicular bisector. Heating it uniformly causes linear expansion: every dimension increases slightly. For a rod, the length L increases, and since the mass stays the same, the moment of inertia changes.
Step-by-Step Reasoning
- Moment of inertia of a rod about its perpendicular bisector For a uniform rod of mass M and length ℓ, rotating about an axis through its centre and perpendicular to its length, the moment of inertia is
I=121Mℓ2.
This is a standard result — the mass is distributed symmetrically, and the factor 121 comes from integrating r2dm.
- Effect of heating on length When the temperature rises by ΔT, the rod expands linearly:
ℓ′=ℓ(1+αΔT),
where α is the coefficient of linear expansion. Since ΔT is small, αΔT≪1.
- New moment of inertia The mass M does not change. The new moment of inertia is
I′=121M(ℓ′)2=121Mℓ2(1+αΔT)2.
Expanding to first order (since αΔT is tiny):
I′≈I(1+2αΔT).
So I′>I — the moment of inertia increases.
- Conservation of angular momentum No external torque acts on the rod (it rotates freely, and heating does not apply a torque). Therefore
Iω=I′ω′.
Substituting I′=I(1+2αΔT) gives
ω′=1+2αΔTω≈ω(1−2αΔT).
Since 2αΔT>0, we have ω′<ω — the angular speed decreases.
A common mistake is to think that because the rod expands outward, its speed increases (like a spinning skater pulling arms in). But here the mass moves away from the axis, increasing I, which slows the rotation — the opposite of the skater effect.
- Checking the options
- (A) says speed increases — wrong.
- (B) says speed decreases — correct.
- (C) says speed remains same — wrong.
- (D) says speed increases because moment of inertia increases — the reason is backwards; increasing I decreases speed.
You can remember this as: heating → expansion → larger I → slower spin (for a free body). The skater’s trick works only when I decreases.
The correct option is (B): its speed of rotation decreases.
Skip computing how much I changes and reason purely from conservation: with no external torque, L=Iω is fixed. Heating a solid rod can only push mass farther from the rotation axis (thermal expansion never shrinks it), so I can only increase, never decrease or stay put. Since ω=L/I with L constant, a larger I can only pull ω down — this rules out (A), (C), and (D) without any calculation, leaving (B) as the sole option consistent with angular-momentum conservation. It's the mirror image of a figure skater pulling their arms out to slow a spin.
Showing the 12 most recent of 60 on this concept.
- AP EAPCET 2026Set eng-2026-05-12-FN1 markMCQQ.A ring of mass 1.5 kg and radius 35 cm is rolling without slipping on a horizontal floor. If the translational kinetic energy of the ring is 100 J, then its rotational kinetic energy is (A) 150 J (B) 50 J (C) 100 J (D) 200 J
›Reveal solutionSolution
A rolling ring always splits its kinetic energy 50:50 between translation and rotation, because its moment of inertia I=MR2 makes the two energy expressions identical in form. Answer: (C) 100 J.
Concept and Intuition
For any object rolling without slipping, translational and rotational kinetic energies are linked through the no-slip condition v=ωR. Whether the two energies are equal, or one dominates, depends entirely on the shape factor k2 in I=Mk2 (where k is the radius of gyration). A ring/hoop has all its mass at radius R, so I=MR2 exactly — this is the special case where the rotational KE expression becomes numerically identical to the translational KE expression once v=ωR is substituted. (Contrast: a solid disc has I=21MR2, so its rotational KE is only half its translational KE; a solid sphere has I=52MR2, giving an even smaller ratio.)
Step-by-Step Solution
- Moment of inertia of a ring about its central axis: I=MR2.
- Rolling without slipping condition: v=ωR, i.e. ω=v/R.
- Rotational KE:
KErot=21Iω2=21(MR2)(Rv)2=21Mv2.
- Compare to translational KE: KEtrans=21Mv2 — identical expression!
- Since KErot=KEtrans for a ring, and we're given KEtrans=100 J, immediately KErot=100 J. (Note: the given mass 1.5 kg and radius 35 cm are not even needed — this ratio is a pure shape property.)
Common Mistakes
- Assuming a rolling object's rotational and translational KEs are always equal for any shape — this only happens for a ring/hoop (I=MR2); for other shapes the ratio is different (e.g. disc: 1:2, sphere: 2:5).
- Getting distracted by trying to compute ω or v numerically from the given mass/radius — they cancel out entirely; the answer follows purely from the ring's shape factor.
✓Final answerThe correct option is (C) — 100 J.
ANSWER: C
- AP EAPCET 2026Set eng-2026-05-12-AN1 markMCQQ.Hollow sphere rolls on an inclined plane of height h without slipping. If it starts from rest, its speed at the bottom is (A) 2gh (B) 710gh (C) 56gh (D) 34gh
›Reveal solutionSolution
Rolling without slipping converts gravitational PE into both translational and rotational KE; using the hollow sphere's moment of inertia I=32mr2 gives v=6gh/5.
Concept and Intuition
When an object rolls without slipping down an incline, its total kinetic energy at the bottom is split between translational motion of the centre of mass and rotation about that centre. The fraction going into rotation depends on the object's moment-of-inertia factor (k2 in I=mk2) — a hollow sphere (k2=32r2) ends up slower at the bottom than a solid sphere (k2=52r2) because more of its mass (and hence energy) is invested in rotation.
Step-by-Step Solution
- Energy conservation (starting from rest, height h): mgh=21mv2+21Iω2.
- For a hollow (thin-walled) sphere: I=32mr2.
- Rolling without slipping: ω=v/r, so 21Iω2=21(32mr2)(r2v2)=31mv2.
- Substitute: mgh=21mv2+31mv2=(63+62)mv2=65mv2.
- Solve for v: v2=56gh⇒v=56gh.
Common Mistakes
- Using the solid-sphere moment of inertia (52mr2, giving 10gh/7) instead of the hollow-sphere value — a very common mix-up between solid and hollow.
- Forgetting the rotational KE term entirely, which would give the (wrong) free-fall answer 2gh.
✓Final answerThe correct option is (C) — 56gh.
ANSWER: C
- AP EAPCET 2026Set eng-2026-05-14-AN1 markMCQQ.The rotational kinetic energy of a solid sphere of mass 3 kg and radius 0.2 m rolling down an inclined plane of height 7m is (nearer to) (A) 80 J (B) 36 J (C) 40 J (D) 60 J
›Reveal solutionSolution
A solid sphere rolling down an incline splits its total kinetic energy in a fixed ratio between translation and rotation; for a solid sphere the rotational share is 2/7 of the total, giving 60 J here.
Concept and Intuition
For rolling without slipping, v=ωR, so translational and rotational kinetic energies are always in a fixed ratio determined by the moment of inertia factor. For a solid sphere, I=52MR2, and this ratio comes out to rotational KE being 2/7 of the total KE — independent of speed, mass, or radius (radius and mass are given here mostly as distractors, though mass does scale the total energy).
Step-by-Step Solution
- Total mechanical energy converted from height (energy conservation, rolling without slipping, no energy loss to friction since it's rolling not sliding): Etotal=Mgh=3×10×7=210 J.
- Total KE at the bottom = translational KE + rotational KE =21Mv2+21Iω2.
- For a solid sphere, I=52MR2 and rolling condition v=ωR: KErot=21⋅52MR2⋅R2v2=51Mv2 KEtrans=21Mv2
- Fraction rotational =51Mv2+21Mv251Mv2=7/101/5=72.
- KErot=72×210=60 J.
Common Mistakes
- Computing total KE but forgetting to split off just the rotational part.
- Using the wrong moment-of-inertia fraction (e.g., using a hollow sphere's 2/3 factor instead of a solid sphere's 2/5).
✓Final answerThe correct option is (D) — 60 J.
ANSWER: D
- AP EAPCET 2026Set eng-2026-05-15-AN1 markMCQQ.A particle executes uniform circular motion with an angular momentum L. Its kinetic energy is doubled and the angular frequency is halved, then its angular momentum becomes (A) 2 L (B) 4 L (C) L/2 (D) L/4
›Reveal solutionSolution
This tests the relation between kinetic energy, angular frequency, and angular momentum in circular motion, KE=21Lω. The answer is (B), 4L.
Concept and Intuition
For a particle in circular motion, angular momentum L=mr2ω and kinetic energy KE=21mr2ω2. Notice that KE=21(mr2ω)ω=21Lω — this links L, KE, and ω directly without needing m or r individually, which is exactly what's needed here since only KE and ω are said to change.
Step-by-Step Solution
- Start from L=mr2ω and KE=21mr2ω2.
- Notice KE=21(mr2ω)⋅ω=21Lω, so L=ω2KE.
- Originally, L=ω2KE.
- After the change: KE′=2KE and ω′=2ω.
- New angular momentum: L′=ω′2KE′=ω/22(2KE)=ω4KE×2=ω8KE.
- Since L=ω2KE, we have ω8KE=4×ω2KE=4L.
Common Mistakes
- Treating m and r as fixed and trying to solve for them individually — it's unnecessary and can lead to inconsistent assumptions; the relation KE=21Lω bypasses this.
- Sign/inversion errors when substituting ω′=ω/2 (dividing by a half doubles instead of halves) — track this carefully.
✓Final answerThe correct option is (B) — 4 L.
ANSWER: B
- AP EAPCET 2026Set eng-2026-05-15-FN1 markMCQQ.A particle is moving in a circular path with constant angular velocity. Its initial angular momentum is L. If the radius of the circle is tripled by keeping angular velocity same, the new angular momentum is (A) 3L (B) 6L (C) 9L (D) 3L
›Reveal solutionSolution
A point particle's angular momentum about the circle's centre is L=mr2ω — it scales with the square of the radius, not linearly. Tripling r while keeping ω fixed multiplies L by 32=9.
Concept and Intuition
It's tempting to think angular momentum scales the same way as linear momentum with radius, but for circular motion L=Iω, and the moment of inertia of a point mass is I=mr2 — quadratic in r. So even though ω is unchanged, tripling the radius has an amplified effect on L because the particle is both farther from the axis (bigger lever arm) and moving faster in absolute terms (since v=rω also increases with r).
Step-by-Step Solution
- Angular momentum of a particle in circular motion: L=Iω=(mr2)ω.
- Given: initial radius r, initial angular momentum L=mr2ω.
- New radius r′=3r, same ω: L′=m(3r)2ω=9mr2ω.
- Since mr2ω=L, we get L′=9L.
Common Mistakes
- Assuming L scales linearly with r (giving 3L) — it actually scales as r2 because I∝r2.
- Confusing this with linear momentum p=mv=mrω, which would scale linearly with r at fixed ω.
✓Final answerThe correct option is (C) — 9L.
ANSWER: C
- AP EAPCET 2026Set ap-2026-05-19-AN1 markMCQQ.A uniform rod of mass m, length l falls with speed v as shown in the figure. Suddenly one of its ends gets stuck to a frictionless hook. Angular velocity of rod just after its end gets stuck is: [FIGURE] (a horizontal rod of mass m and length l falling vertically with speed v; one end of the rod is approaching a fixed frictionless hook mounted on a wall to its right) (A) 2l3v (B) lv (C) l2v (D) 4l3v
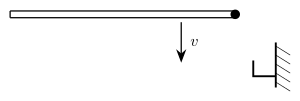
›Reveal solutionSolution
The rod’s end suddenly sticks to a frictionless hook, so angular momentum about the hook is conserved during the collision. The initial angular momentum comes from the rod’s linear motion, and the final angular momentum is that of the rod rotating about the hook. Solving gives ω=2l3v, which corresponds to option (A).
Concept and Intuition
When the rod’s end snags on the frictionless hook, the hook exerts an impulsive force on that end. Because the hook is frictionless, this force passes through the hook point — it has no torque about the hook itself. Therefore, angular momentum of the rod about the hook is conserved during the very brief collision. The rod initially has no rotation, only downward translation. After the catch, it rotates about the hook as a rigid body. We equate the angular momentum just before and just after the catch.
Watch outA common mistake is to try to use conservation of linear momentum or energy. The hook exerts an external force, so linear momentum is not conserved. Energy is also not conserved because the collision is inelastic (the end sticks). Only angular momentum about the hook is conserved.
Step-by-step solution
-
Set up the coordinate system and initial conditions
The rod is horizontal, length l, mass m, falling straight down with speed v. Its center of mass (CM) is at the midpoint. Just before the catch, the right end is about to touch the hook. The rod has no rotation — it’s purely translating downward.
-
Angular momentum about the hook just before the catch
The hook is at the right end of the rod. For a point mass dm at a horizontal distance x from the hook (measured leftward along the rod), its velocity is v downward. The angular momentum of that mass element about the hook is
dL=(x)(v)dm
because the perpendicular distance from the hook to the velocity vector is x, and the direction (into the page) is the same for all elements.
Integrate over the rod: dm=lmdx, with x from 0 (at the hook) to l (at the left end).
Linitial=∫0lxvlmdx=lmv∫0lxdx=lmv⋅2l2=21mvl.
TipThis is the same as the angular momentum of a point mass m at the rod’s center of mass, because the CM is at distance l/2 from the hook: L=(l/2)(mv)=21mvl. That’s a quick check.
- Angular momentum about the hook just after the catch After the end sticks, the rod rotates rigidly about the hook with angular velocity ω (clockwise, say). The moment of inertia of a uniform rod about one end is
Iend=31ml2.
Hence the final angular momentum is
Lfinal=Iendω=31ml2ω.
- Conservation of angular momentum No external torque about the hook acts during the collision, so
Linitial=Lfinal⇒21mvl=31ml2ω.
Cancel m and l (both nonzero):
21v=31lω⇒ω=2l3v.
- Match with options The result 2l3v corresponds to option (A).
For a rod of length l falling with speed v and catching at one end, the angular speed after the catch is ω=2l3v.
✓Final answerThe correct option is (A).
ANSWER: A
-
- AP EAPCET 2026Set ap-2026-05-20-FN1 markMCQQ.A uniform rod of mass 20 kg and length 1.6 m is pivoted at its one end and can swing freely in the vertical plane. The angular acceleration of the rod just after the rod is released from rest in the horizontal position is (g – acceleration due to gravity) (A) 1615g (B) 1617g (C) 1516g (D) 169g
›Reveal solutionSolution
Use τ=Iα for a rod pivoted at one end and released from horizontal; α=2L3g=1615g for L=1.6m.
Concept and Intuition
When a uniform rod pivoted at one end is released from horizontal, gravity acting at its centre of mass produces a torque about the pivot. Newton's second law for rotation, τ=Iα, with I the moment of inertia of the rod about the pivoted end, gives the initial angular acceleration.
Step-by-Step Solution
- Moment of inertia of a uniform rod about one end: I=3mL2.
- Weight mg acts at the centre, a distance L/2 from the pivot; when horizontal, this is the full perpendicular lever arm, so torque τ=mg⋅2L.
- Newton's second law for rotation: τ=Iα⇒mg2L=3mL2α.
- Solve: α=2L3g.
- Substitute L=1.6m: α=3.23g=0.9375g=1615g.
Common Mistakes
- Using I=mL2/12 (about the centre) instead of mL2/3 (about the end).
- Forgetting mass cancels out of the equation, leading to unnecessary numeric mass substitution errors.
✓Final answerThe correct option is (A) — 1615g.
ANSWER: A
- AP EAPCET 2026Set ap-2026-05-20-AN1 markMCQQ.A uniform solid cylinder of mass m and radius R is pulled along a horizontal smooth road by a horizontal force F applied at its center of mass. If the cylinder rolls without slipping, the angular acceleration α of the cylinder is: (A) 2mRF (B) 2mR3F (C) 3mR2F (D) 3mRF
›Reveal solutionSolution
Combining Newton's second law, the torque equation about the centre, and the rolling constraint for a cylinder pulled by a horizontal force at its centre gives α=2F/3mR. Answer: (C).
Concept and Intuition
A force applied exactly through the centre of mass produces zero torque about that centre by itself — so on its own it cannot make the cylinder spin. It is friction at the contact point that supplies the torque needed to keep the cylinder rolling without slipping as it's dragged forward. The trick is to write both the translational equation (net force = ma) and the rotational equation (net torque about the centre = Iα) and tie them together with the no-slip condition a=αR.
Step-by-Step Solution
- Translational: F−f=ma (friction f opposes the forward pull as it acts backward at the contact point to prevent slipping).
- Rotational about the centre: fR=Iα=21mR2α (moment of inertia of a solid cylinder about its axis is 21mR2).
- Rolling constraint: a=αR⇒α=a/R.
- From step 2: f=21mRα=21ma.
- Substitute into step 1: F−21ma=ma⇒F=23ma⇒a=3m2F.
- α=Ra=3mR2F.
Common Mistakes
- Assuming the pulling force itself produces the torque (it can't — it passes through the centre, moment arm zero); it's friction that does.
- Forgetting the rolling constraint a=αR, which is what links the translational and rotational equations into one solvable system.
✓Final answerThe correct option is (C) — 3mR2F.
ANSWER: C
- AP EAPCET 2025Set eng-2025-05-22-AN1 markMCQQ.A solid sphere of mass 4 kg and radius 28 cm is on an inclined plane. If the acceleration of the sphere when it rolls down without sliding is 3.5 ms−2, then the acceleration of the sphere when it slides down without rolling is (A) 2.5 ms−2 (B) 3.5 ms−2 (C) 1.7 ms−2 (D) 4.9 ms−2
›Reveal solutionSolution
Rolling acceleration is reduced from the sliding value by the sphere's moment-of-inertia factor; back-solving the given rolling acceleration recovers gsinθ, which is exactly the sliding (frictionless) acceleration — 4.9 m/s².
Concept and Intuition
For an object rolling without slipping down an incline, part of the gravitational potential energy goes into rotational kinetic energy, so its linear (translational) acceleration is less than gsinθ: aroll=1+I/(mr2)gsinθ. For a solid sphere, I=52mr2, so aroll=1+2/5gsinθ=75gsinθ. If instead it slides down without rolling (frictionless, no rotation), all the energy goes into translational KE, giving simply aslide=gsinθ — independent of mass, radius, or moment of inertia.
Step-by-Step Solution
- Rolling acceleration: aroll=75gsinθ=3.5 m/s2.
- Solve for gsinθ: gsinθ=57×3.5=4.9 m/s2.
- Sliding (frictionless) acceleration is exactly this value: aslide=gsinθ=4.9 m/s2.
Common Mistakes
- Trying to use the sphere's actual mass (4 kg) or radius (28 cm) — they're irrelevant distractors since aroll and aslide depend only on gsinθ and the moment-of-inertia factor.
- Mixing up the factor for a solid sphere (2/5) with that of a disc (1/2) or shell (2/3).
✓Final answerThe correct option is (D) — 4.9 ms−2.
ANSWER: D
- AP EAPCET 2025Set eng-2025-05-22-FN1 markMCQQ.A thin uniform circular disc rolls with a constant velocity without slipping on a horizontal surface. Its total kinetic energy is (A) three times its rotational kinetic energy (B) three times its translational kinetic energy (C) one and half times its rotational kinetic energy (D) twice its translational kinetic energy
›Reveal solutionSolution
For a rolling disc, total KE splits as 43Mv2 (total), 41Mv2 (rotational), 21Mv2 (translational) — total is 3× the rotational part.
Concept and Intuition
Rolling without slipping links the disc's rotational and translational motion via v=ωR. A disc's moment of inertia (I=21MR2) is smaller than, say, a ring's (MR2), which means for a disc the translational KE dominates over the rotational KE — the exact ratio is what this question checks.
Step-by-Step Solution
- Moment of inertia of a disc about its central axis: I=21MR2.
- Rolling without slipping: v=ωR⇒ω=Rv.
- Rotational KE: KErot=21Iω2=21⋅21MR2⋅R2v2=41Mv2.
- Translational KE: KEtrans=21Mv2.
- Total KE: KEtotal=KEtrans+KErot=21Mv2+41Mv2=43Mv2.
- Ratio total to rotational: KErotKEtotal=1/43/4=3. So total KE is three times the rotational KE. (Check against translational: KEtransKEtotal=1/23/4=1.5, i.e. total is 1.5× translational — not matching options (B)/(C), confirming (A) is the only correct statement.)
Common Mistakes
- Using a ring's or sphere's moment of inertia instead of a disc's 21MR2.
- Comparing total KE to translational KE and picking option (B) or (C), which describe the wrong ratio.
✓Final answerThe correct option is (A) — three times its rotational kinetic energy.
ANSWER: A
- AP EAPCET 2025Set eng-2025-05-23-FN1 markMCQQ.A thin circular ring and a circular disc of equal mass are rolling without sliding. If their linear velocities are equal and the total kinetic energy of the disc is 6 J, then the total kinetic energy of the ring is (A) 6 J (B) 3 J (C) 8 J (D) 4 J
›Reveal solutionSolution
This tests total kinetic energy (translational + rotational) for rolling bodies with different moments of inertia but equal mass and linear speed. Answer: (C).
Concept and Intuition
For any body rolling without slipping, total KE =21mv2(1+mr2I), where mr2I is a shape-dependent factor (a pure number): 21 for a disc, 1 for a ring. So bodies with the same mass and linear speed will still have different total KE purely because of this shape factor.
Step-by-Step Solution
- Total KE of a rolling body: KE=21mv2+21Iω2, and for rolling without slipping ω=v/r.
- For the disc, Idisc=21mr2:
KEdisc=21mv2+21(21mr2)(rv)2=21mv2+41mv2=43mv2.
Given KEdisc=6 J, so 43mv2=6⟹mv2=8.
3. For the ring, Iring=mr2:
KEring=21mv2+21(mr2)(rv)2=21mv2+21mv2=mv2.
- So KEring=mv2=8 J (using the value found in step 2).
Common Mistakes
- Assuming equal KE for equal mass and speed — the rotational contribution depends on the mass distribution (moment of inertia), so a ring (all mass at the rim) always has more rotational KE than a disc of the same mass, radius and linear speed.
- Forgetting the rotational KE term entirely and treating this as pure translational motion.
✓Final answerThe correct option is (C) — 8 J.
ANSWER: C
- AP EAPCET 2025Set ap-2025-05-19-AN1 markMCQQ.If a solid sphere of mass 50 g and diameter 20 cm rolls without slipping with a velocity 5 cm s−1 on a surface, then its total kinetic energy is (A) 6.25×10⁻⁷ J (B) 2.50×10⁻⁷ J (C) 8.75×10⁻⁵ J (D) 3.75×10⁻⁵ J
›Reveal solutionSolution
Tests total (translational + rotational) kinetic energy of a rolling solid sphere; the diameter given is a distractor (not needed, since v is given directly).
Concept and Intuition
For any body rolling without slipping, the point of contact is instantaneously at rest, so the body's motion is a pure translation of the center of mass plus a pure rotation about that center — both energies add. Writing ω=v/R, the rotational KE becomes 21Iω2=21(R2k2)mv2, so total KE is 21mv2(1+R2k2). For a solid sphere, I=52MR2, i.e. k2/R2=2/5.
Step-by-Step Solution
- m=50 g=0.05 kg, v=5 cm/s=0.05 m/s.
- For a solid sphere, R2k2=52, so total KE factor =1+52=57.
- Total KE =21mv2×57=21(0.05)(0.0025)×1.4.
- 21(0.05)(0.0025)=6.25×10⁻⁵; multiplying by 1.4 gives 8.75×10⁻⁵ J.
Common Mistakes
- Using only translational KE (21mv2), ignoring the rolling constraint's rotational contribution.
- Using the wrong k2/R2 (e.g. 2/3 for a hollow sphere instead of 2/5 for solid).
- Getting distracted by the diameter value — it is not needed since v is already given.
✓Final answerThe correct option is (C) — 8.75×10⁻⁵ J.
ANSWER: C
🎓Unlock everything free for 14 days
- ✓Full step-by-step solutions
- ✓Concept-first explanations
- ✓Methods, shortcuts & mistakes
- ✓PYQ mapping + timed mock tests
Full access for 14 days. No credit card required.