Mathematics · Ch 10 — Vector Algebra
Vector (or Cross) Product of Two Vectors
Vector (or Cross) Product of Two Vectors
Vector (or Cross) Product of Two Vectors
The Right-Handed Coordinate System
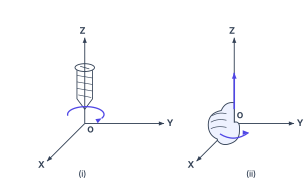
In a right-handed rectangular coordinate system, if you curl the fingers of your right hand from the positive x-axis toward the positive y-axis, your thumb points along the positive z-axis. Equivalently, a right-handed screw rotated from the x-axis toward the y-axis advances along the positive z-axis. This orientation underlies the definition of the cross product.
Definition of the Vector (Cross) Product
For two nonzero vectors and , their vector product (also called cross product) is denoted and defined as:
where:
- is the angle between and , with
- is a unit vector perpendicular to both and
- , , form a right-handed system
When you rotate from toward , the direction of is the direction in which a right-handed screw would advance.
If either or , then is not defined, and we define .
Observations About the Cross Product
Observation 1: The Result is a Vector
Unlike the dot product, which gives a scalar, is always a vector.
Observation 2: Parallel Vectors
For nonzero and , if and only if and are parallel (collinear), since then or , making .
In particular, and .
Observation 3: Perpendicular Vectors
If , then , so:
Observation 4: Cross Products of Unit Vectors
For the mutually perpendicular right-handed unit vectors , , :
Going forward in the cycle gives the next unit vector (positive); going backward gives its negative.
Observation 5: Finding the Angle Between Vectors
Observation 6: Non-Commutativity
The vector product is not commutative:
›Proof
and have the same magnitude. But if and lie in the plane of the paper, points above the paper while points below, so . Therefore .
Observation 7: Cross Products in Reverse Order
From Observations 4 and 6:
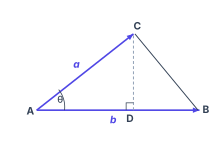
Observation 8: Area of a Triangle
If and represent the adjacent sides of a triangle, its area is .
›Proof
For triangle ABC with AB , AC and included angle : Area , where CD is the perpendicular from C to AB. Thus Area .
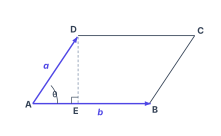
Observation 9: Area of a Parallelogram
If and represent the adjacent sides of a parallelogram, its area is .
›Proof
For parallelogram ABCD with AB , AD : Area , where DE is the perpendicular from D to AB. Thus Area .
Properties of the Vector Product
Property 3: Distributivity of Vector Product Over Addition
If , , are any three vectors, then:
(i)
(ii)
The distributive property holds, but the cross product is not commutative. So is not the same as .
Cross Product in Component Form …
Definition
The vector product (or cross product) of two nonzero vectors and is denoted by and is defined as:
where:
- is the angle between and , with .
- is a unit vector perpendicular to both and , such that , , and form a right-handed system.
Right-handed system: If you curl the fingers of your right hand from toward , your thumb points in the direction of .
Special case: If either or , then is not defined, and we define .
Intuition
The cross product gives a new vector whose:
- magnitude equals the area of the parallelogram formed by and ,
- direction is perpendicular to the plane containing and , following the right-hand rule.
Tiny Example …
Distributivity of vector product over addition: For any three vectors , , and a scalar :
- …
Drawn by us to help you understand the concept clearly, and verified to make sure it's accurate. For exams, practice from your textbook's own diagram.
Fig 10.22 is the textbook’s visual anchor for the right-handed coordinate system — the convention that governs the direction of the cross product. The figure has two panels, (i) and (ii), each showing the same idea from a different angle.
Panel (i) shows the three axes , , meeting at the origin . A right-handed screw is placed along the -axis. An indigo curved arrow on the -plane indicates a rotation from the positive -axis toward the positive -axis. As that rotation happens, the screw advances upward along the positive -direction. This is the physical rule: a counterclockwise turn from to drives a screw forward in .
Panel (ii) replaces the screw with a right hand placed at the origin. The fingers curl from the positive -axis toward the positive -axis (again shown by an indigo curved arrow). The thumb, drawn as an indigo arrow, points straight up along the positive -axis. This is the familiar right-hand rule: curl your fingers from the first vector to the second, and your thumb gives the direction of the cross product.
Both panels teach the same geometric fact: the triplet forms a right-handed system. This is not arbitrary — it is the standard convention used throughout physics and engineering. When you take the cross product , the resulting vector is perpendicular to both and , and its direction is given by this same right-hand rule.
The textbook uses this figure to ground Definition 3 of the vector product:
Here is the angle between and (), and is a unit vector perpendicular to both and . The triplet must form a right-handed system — exactly the convention Fig 10.22 illustrates. If you rotate into through the smaller angle, a right-handed screw would advance in the direction of .
The cross product is not commutative. Swapping the order reverses the direction: . The right-hand rule makes this clear — curling from to gives a thumb pointing opposite to .
For the unit vectors along the axes, Fig 10.22 directly implies the cyclic relations: …
Drawn by us to help you understand the concept clearly, and verified to make sure it's accurate. For exams, practice from your textbook's own diagram.
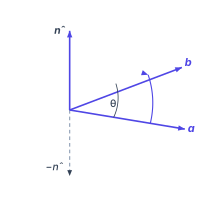
Fig 10.23 is the defining diagram for the cross product. It shows two vectors a and b drawn from a common origin, with the angle between them marked by a thin arc. A curved arrow sweeps from a to b, indicating the sense of rotation that determines the direction of the result.
The key feature is the unit vector , shown as a vertical indigo arrow pointing upward. This vector is perpendicular to the plane containing a and b. Its direction is fixed by the right-hand rule: if you curl the fingers of your right hand from a toward b through the smaller angle , your thumb points along . The dashed slate arrow pointing downward represents , the opposite perpendicular direction — a reminder that the cross product is not commutative and that reversing the order of the vectors reverses the sign.
The cross product is a vector, not a scalar. Its magnitude is , and its direction is given by , which is perpendicular to both and .
The central formula the figure illustrates is the definition of the vector (cross) product:
Here:
- and are the magnitudes (lengths) of the two vectors.
- is the smaller angle between them, with .
- is a unit vector perpendicular to the plane containing and , oriented so that , , and form a right-handed system.
The diagram makes two physical ideas clear. First, the magnitude equals the area of the parallelogram spanned by and — that area is , which is exactly the product of the two magnitudes and the sine of the included angle. Second, the direction of is unique only up to a sign; the right-hand rule picks the correct one. If you swap the order to , the same right-hand rule gives , so .
A common mistake is to think the cross product gives a scalar. It does not — it gives a vector perpendicular to the plane of the two original vectors. The sine factor means that if and are parallel ( or ), the cross product is the zero vector, not a zero scalar. …
Drawn by us to help you understand the concept clearly, and verified to make sure it's accurate. For exams, practice from your textbook's own diagram.
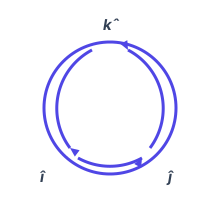
Fig 10.24 is a compact visual mnemonic for the cross products of the three mutually perpendicular unit vectors , , and in a right-handed coordinate system. The figure shows a circle with three equally spaced points labelled by these unit vectors. At the top of the circle is ; at the lower-left is ; at the lower-right is . Curved arrows run along the circumference in the cyclic order (along the bottom), (up the right side), and (down the left side). Each arrow indicates the direction of the first vector going to the second in a cross product.
The physical idea is simple: if you move forward (in the direction of the arrow) from one unit vector to the next, the cross product gives the third unit vector, and it is positive. For example, following the arrow from to yields . If you go backward (against the arrow), the cross product is negative. This cyclic pattern encodes all nine cross products among without memorising a table.
Each of these follows from the right-hand rule: when you curl the fingers of your right hand from the first vector to the second, your thumb points in the direction of the cross product. The figure makes the cyclic symmetry obvious — moving one step clockwise (in the order shown) gives a positive result; moving one step anticlockwise gives a negative result, as in .
The cross product is not commutative. Reversing the order flips the sign: but . The figure’s arrows only show the positive cycle; the opposite direction gives the negative result.
The textbook uses this figure immediately after defining the vector product and before stating Observation 4, which lists these three fundamental cross products. It also serves as a visual anchor for the determinant formula that follows later in the section:
where and . The cyclic pattern in Fig 10.24 is exactly what the determinant expansion produces: each term picks out a cyclic permutation of the indices. …
Drawn by us to help you understand the concept clearly, and verified to make sure it's accurate. For exams, practice from your textbook's own diagram.
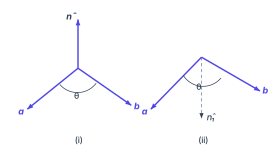
Fig 10.25 is the visual heart of the non-commutativity of the cross product. It shows two panels, (i) and (ii), each containing the same two vectors and lying in the plane of the paper. In both panels, and are drawn from a common origin, splaying downward-left and downward-right respectively, with the smaller angle between them labelled .
The critical difference between the two panels is the direction of the unit normal vector.
In panel (i), the cross product is considered. The unit normal is shown as a solid indigo arrow pointing straight up, out of the plane of the paper. This direction is determined by the right-hand rule: curl the fingers of your right hand from toward through the angle , and your thumb points in the direction of — here, upward.
In panel (ii), the cross product is considered. The unit normal is shown as a dashed slate arrow pointing straight down, into the plane of the paper. Applying the same right-hand rule, but now curling from toward , your thumb points downward. The figure makes it geometrically obvious that .
The central formula that this figure grounds is the anti-commutative property of the cross product:
Here, and are any two non-zero vectors in three-dimensional space, and the cross product is defined as , where is the angle between them () and is a unit vector perpendicular to both and such that form a right-handed system. The figure shows that reversing the order of the vectors in the product reverses the direction of the unit normal, which flips the sign of the entire vector result.
A common mistake is to think the cross product is commutative like the dot product. Fig 10.25 is designed to kill that instinct. The magnitude is the same in both panels, but the direction is opposite. The cross product is anti-commutative, not commutative. …
Drawn by us to help you understand the concept clearly, and verified to make sure it's accurate. For exams, practice from your textbook's own diagram.
Fig 10.26 is a simple triangle drawn in a plane, labelled ABC. Vertex A is at the lower left, B at the lower right, and C at the top. The side AB runs along the base, and the side AC slopes upward from A to C. The vector from A to B is labelled b, and the vector from A to C is labelled a. The angle at vertex A, between a and b, is marked .
The key geometric addition is a dashed altitude from C down to the base AB, meeting AB at point D. A small right-angle square is drawn at D, confirming that CD is perpendicular to AB. This altitude is not a vector in the diagram — it is a length, the perpendicular height of the triangle.
What the figure teaches is the link between the cross product of two vectors and the area of the triangle they span. The area of triangle ABC is . But AB is the magnitude , and CD is the height measured from C to the base. Since AC = and the angle at A is , the altitude CD equals . So
The right-hand side is exactly half the magnitude of the cross product: .
…
Drawn by us to help you understand the concept clearly, and verified to make sure it's accurate. For exams, practice from your textbook's own diagram.
Fig 10.27 is a clean geometric diagram of a parallelogram labelled ABCD. Vertex A is at the lower left, B at the lower right, C at the upper right, and D at the upper left. The side AB runs horizontally along the bottom, and AD runs upward to the left from A. The top side DC is parallel to AB, and the right side BC is parallel to AD. The vector is drawn along AD, and the vector is drawn along AB. The angle between these two vectors is marked as at vertex A.
The key visual addition is a dashed vertical line from D down to the base AB, meeting AB at point E. A small right-angle square is drawn at E, confirming that DE is perpendicular to AB. This dashed line DE represents the height of the parallelogram when AB is taken as the base.
The physical idea is straightforward: the area of a parallelogram equals base times height. Here the base is (the length of AB), and the height is (the length of DE). The figure makes it geometrically obvious why the magnitude of the cross product gives this area.
The textbook uses this figure to derive the central formula for the area of a parallelogram formed by two adjacent vectors:
The derivation follows directly from the diagram. Since AB and AD , the base length is . The height DE is the perpendicular distance from D to AB, which equals (the component of perpendicular to ). Multiplying base by height gives , which is precisely the definition of . …