Physics · Ch 13 — Oscillations
The Simple Pendulum
The Simple Pendulum
The Simple Pendulum: A Model for Oscillation
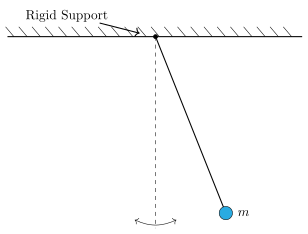
A simple pendulum is one of the most familiar examples of oscillatory motion. It consists of a point mass (called the bob) suspended from a fixed point by a massless, inextensible string. When the bob is pulled to one side and released, it swings back and forth about its equilibrium position (the vertical line through the pivot). The question is: does this motion qualify as simple harmonic motion (SHM)?
The answer is yes, but only under a specific condition — when the angular displacement is small. Let’s see why.
The Restoring Force and Torque
When the pendulum is displaced by an angle from the vertical, the forces acting on the bob are:
- its weight acting vertically downward,
- the tension in the string acting along the string toward the pivot.
The weight has two components:
- along the string, balanced by the tension,
- tangential to the arc of motion, which acts as the restoring force.
This tangential component always points toward the equilibrium position. For small angles, (in radians), so the restoring force is approximately proportional to the displacement along the arc.
But the motion is rotational about the pivot, not purely linear. It’s more natural to work with the restoring torque about the pivot. The torque due to the tangential force is:
where is the length of the pendulum (distance from pivot to bob). The negative sign indicates that the torque always acts to reduce — it’s a restoring torque.
For small , , so:
The Equation of Motion
The rotational analogue of Newton’s second law is , where is the moment of inertia about the pivot and is the angular acceleration. For a point mass at distance , .
Substituting:
Cancel from both sides:
Rearranging gives the differential equation for the simple pendulum:
This is exactly the same form as the SHM equation , with playing the role of the displacement variable. Therefore, for small angular displacements, the simple pendulum executes SHM.
Angular Frequency and Time Period
Comparing with the standard SHM equation, we identify:
So the angular frequency is:
The time period is related to by , giving:
This is the famous formula for the time period of a simple pendulum. Notice that depends only on the length and the acceleration due to gravity . It does not depend on the mass of the bob or the amplitude of oscillation (as long as the amplitude is small).
The time period of a simple pendulum is independent of the mass of the bob and the amplitude (for small oscillations). It depends only on and .
Properties of Simple Pendulum Motion
The textbook lists three key properties that follow from the SHM analysis. Each is derived below.
Property 1: The motion is simple harmonic for small angular displacements.
We have already shown this. The restoring torque is proportional to (for small ), leading to the SHM differential equation. The angular displacement varies sinusoidally with time:
where is the maximum angular displacement (amplitude) and is the initial phase.
›Proof
The general solution of is , which can be written as . This satisfies the equation for any constants and , confirming SHM.
Property 2: The time period is independent of the amplitude (for small oscillations).
From , there is no term. This is a hallmark of SHM — the period is constant regardless of how far you pull the bob (within the small-angle limit). For larger amplitudes, the approximation breaks down, and the period actually increases slightly with amplitude.
Property 3: The time period is independent of the mass of the bob.
The derivation of involved cancelling from both sides of the torque equation. Physically, a heavier bob experiences a larger restoring force, but also has a larger inertia — the two effects cancel exactly. This is why a pendulum’s period doesn’t change if you swap the bob for a heavier or lighter one (keeping fixed).
The Small-Angle Approximation: Why It Matters
The condition “for small angles” is crucial. If is not small, , and the differential equation becomes:
…
Drawn by us to help you understand the concept clearly, and verified to make sure it's accurate. For exams, practice from your textbook's own diagram.
The figure shows a simple pendulum drawn from a hatched support at the top. A string of length (coloured blue) hangs straight down to a bob of mass . A vertical dashed line runs through the support point — this is the equilibrium or mean position, the line the string would follow if the bob were perfectly still. A curved double-headed arrow sweeps across the top of the diagram, marking the angular displacement of the string from that vertical reference. The arrow is drawn as an arc, not a straight line, because the bob’s path is a circular arc of radius .
The physical idea is straightforward: when you pull the bob sideways and release it, gravity provides a restoring force that tries to bring it back to the dashed vertical line. But because the bob is constrained to move along a circular arc, the restoring force is not simply — it is the component of gravity tangent to the arc. That tangential component is , where the minus sign indicates it always points opposite to the displacement. For small angles (typically or so), (with in radians), and the motion becomes simple harmonic.
The simple pendulum is only a simple harmonic oscillator for small angular displacements. The approximation is the key that linearises the equation of motion.
From Newton’s second law applied to the tangential direction, you get
For small , replace with :
This is exactly the differential equation of SHM, with angular frequency
The period — the time for one complete oscillation — follows immediately:
Every symbol has a clear meaning: is the period (in seconds), is the string length (in metres), and is the acceleration due to gravity (about on Earth). Notice that the period does not depend on the mass of the bob or on the amplitude (as long as the amplitude is small). This is a striking result — a heavier bob and a lighter bob of the same string length swing with exactly the same period.
Do not confuse the angular frequency (radians per second) with the angular speed of the bob. Here is a constant of the motion, not the instantaneous rate of change of . …
Drawn by us to help you understand the concept clearly, and verified to make sure it's accurate. For exams, practice from your textbook's own diagram.
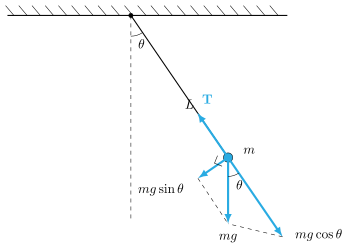
The figure shows a simple pendulum bob at an instant when the string makes an angle with the vertical. The bob’s weight acts straight down. Two dashed lines through the bob show the directions of the string (radial) and the tangent to the circular arc (tangential). The tension in the string is drawn as a blue arrow along the string, pointing toward the pivot.
The weight is resolved into two components: along the string (dashed, pointing away from the pivot) and tangential to the arc (dashed, pointing in the direction of decreasing ). The radial component provides the centripetal force needed to keep the bob moving in a circle — but because this force passes through the pivot, it exerts no torque about the pivot. The tangential component does produce a torque about the pivot, and it always acts to restore the bob toward the equilibrium position (). This is the restoring torque.
The key physical idea is that the pendulum’s motion is driven entirely by the tangential component of gravity. The radial forces (tension and the radial part of weight) only constrain the bob to move on a circular path; they do not affect the angular acceleration.
The restoring torque about the pivot is , where is the length of the string. The negative sign indicates that the torque always opposes the angular displacement .
For small angles ( in radians), , so the torque becomes approximately . Using with moment of inertia for a point mass at distance , we get
This is the equation of simple harmonic motion with angular frequency
The period is therefore
…
| theta (degrees) | theta (radians) | sin(theta) |
|---|---|---|
| 0 | 0 | 0 |
| 5 | 0.087 | 0.087 |
| 10 | 0.174 | 0.174 |