Mathematics · Ch 12 — Linear Programming
Graphical Method of Solving Linear Programming Problems
Graphical Method of Solving Linear Programming Problems
12.2.2 Graphical Method of Solving Linear Programming Problems
From Inequalities to Optimization
In Class XI you learned to graph a system of linear inequalities in two variables and find the solution region. The graphical method for linear programming builds directly on that skill — but instead of just finding where all constraints are satisfied, we search that region for the point giving the best (maximum or minimum) value of a linear objective function.
Revisit the investment problem from Section 12.2:
where = number of tables and = number of chairs. The objective is to maximize profit .
The Feasible Region
Graphing all four inequalities, the shaded region common to all half-planes is the feasible region — in Fig 12.1 of the textbook, the quadrilateral OABC.
Feasible region: The common region determined by all constraints (including , ) of a linear programming problem.
Every point inside or on the boundary is a feasible solution — for example (10, 50), (0, 60), (20, 0). Any point outside, such as (25, 40), is an infeasible solution.
Points on the boundary are also feasible — they satisfy the constraints as equalities. It is a mistake to think only points strictly inside the region are feasible.
The Challenge: Finding the Optimal Point
The feasible region contains infinitely many points, so we cannot check each one. Two fundamental theorems (stated here without proof) solve this problem.
Theorem 1: The Corner Point Principle
Theorem 1: Let be the feasible region for a linear programming problem, and the objective function. When has an optimal value (maximum or minimum), this value must occur at a corner point (vertex) of .
A corner point is where two boundary lines intersect. So instead of checking every point, we only examine the vertices.
Theorem 2: Existence of Optima for Bounded Regions
Theorem 2: If the feasible region is bounded (can be enclosed within a circle), then has both a maximum and a minimum value on , each occurring at a corner point of .
If is unbounded (extends indefinitely), a maximum or minimum may not exist. However, if an optimal value does exist, it still occurs at a corner point (by Theorem 1).
The Corner Point Method
-
Find the feasible region and its corner points, by inspection or by solving the equations of the intersecting lines at each vertex.
-
Evaluate at each corner point. Let be the largest value and the smallest.
-
Determine optimal values:
- (i) If is bounded, is the maximum value and the minimum value of .
- (ii) If is unbounded:
- (a) is the maximum value if and only if the open half-plane has no point in common with ; otherwise has no maximum.
- (b) is the minimum value if and only if the open half-plane has no point in common with ; otherwise has no minimum.
The extra check for unbounded regions is crucial: even if a corner point gives the smallest value among all vertices, a point elsewhere in the region might give an even smaller value. …
Theorem 2: The Corner-Point Theorem for Bounded Feasible Regions
Statement (from NCERT Class 12):
Let be the feasible region for a linear programming problem, and let be the objective function. If is bounded, then the objective function has both a maximum and a minimum value on , and each of these occurs at a corner point (vertex) of .
What the hypotheses mean
- Feasible region is the set of all points that satisfy every constraint (including ). Graphically, it is the common shaded region formed by all the half-planes.
- Bounded means the region can be enclosed inside some circle of finite radius. In other words, it does not stretch off to infinity in any direction. A bounded feasible region is always a convex polygon (or a line segment, or a single point).
- Objective function is a linear function whose value we want to maximise or minimise.
The theorem guarantees both a maximum and a minimum exist when the region is bounded. This is not true for unbounded regions — there, a maximum or minimum may not exist at all.
Complete Proof
›Proof
Step 1: The feasible region is a closed, bounded convex polygon.
Since is defined by a finite set of linear inequalities, its boundary consists of straight line segments. Because is bounded, it has a finite number of corner points (vertices). Let these vertices be .
Step 2: Any point in can be expressed as a convex combination of the vertices.
This is a property of convex polygons: every point inside or on the boundary of can be written as
where for all and .
Step 3: Evaluate at such a point.
Since is linear, we have:
So the value of at any point is a weighted average of its values at the vertices, with the same weights .
Step 4: The maximum of occurs at a vertex.
Let be the largest value among the vertices. Then for any point in :
Therefore, no point in can give a value larger than . Since is actually attained at some vertex (by definition), the maximum value of on is exactly , and it occurs at that vertex.
Step 5: The minimum of occurs at a vertex.
Let be the smallest value among the vertices. Then for any point in :
So no point gives a value smaller than , and is attained at some vertex. Hence the minimum value is , occurring at a vertex.
Step 6: Both extremal values exist.
Because is bounded and closed, the continuous function must attain both a maximum and a minimum on (by the Extreme Value Theorem from calculus). Steps 4 and 5 show these must be at vertices. This completes the proof.
When is this theorem used? …
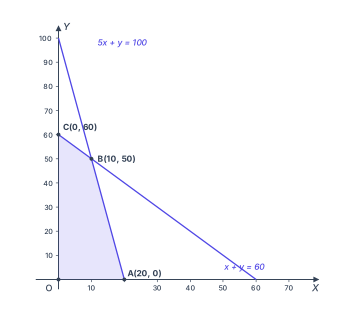
Drawn by us to help you understand the concept clearly, and verified to make sure it's accurate. For exams, practice from your NCERT textbook's own diagram.
Fig 12.1 is the first graphical illustration of a linear programming problem in the chapter. It shows the feasible region for the tables-and-chairs investment problem, and it is the picture that makes the entire Corner Point Method intuitive.
The graph is drawn in the first quadrant only, because the non-negativity constraints and restrict everything to positive and . The horizontal axis is labelled (number of tables), and the vertical axis is (number of chairs). Two straight lines are drawn across this quadrant:
- The indigo line cuts the -axis at and the -axis at .
- The line cuts the -axis at and the -axis at .
These two lines intersect at point , whose coordinates are . That intersection is the key — it is where both constraints are simultaneously tight.
The region that satisfies all four constraints — , , , — is the polygon , shaded light indigo. Its vertices are:
- — the origin, where nothing is bought.
- — on the -axis, where meets the -axis.
- — the intersection of the two constraint lines.
- — on the -axis, where meets the -axis.
Every point inside or on the boundary of this polygon is a feasible solution — a combination of tables and chairs that does not exceed the dealer's budget or storage capacity. Points outside, like , are infeasible because they violate at least one constraint.
The feasible region is always a convex polygon. Here it is bounded (it can be enclosed in a circle), so both a maximum and a minimum value of the objective function exist, and they occur at corner points.
The objective function for this problem is the profit:
where is the number of tables (profit ₹250 per table) and is the number of chairs (profit ₹75 per chair). The textbook evaluates at each corner point:
| Vertex | Coordinates | (₹) |
|---|---|---|
| ← maximum | ||