Q.(vii) The solution of dxdy=(xy)1/3 is y2/3−x2/3=c. (State True or False.)
🔒You're viewing a preview — the full solution, concept, methods & PYQ mapping are locked.
🔒 Start your 14-day free trial to unlock the full solution →Concept understanding — Verification of Solution
Verifying a Solution of a Differential Equation
A function y=ϕ(x) is called a solution of a differential equation if, when you substitute it and its derivatives into the equation, the two sides become equal for every x in the domain. Verification is the act of carrying out that substitution and checking that it holds as an identity.
The useful point: you do not have to solve the equation to verify a candidate. You are only checking a function that is already handed to you — which is exactly how many exam questions are phrased: "Show that … is a solution of …."
The steps
- From the given y=ϕ(x), compute exactly the derivatives that appear in the equation.
- Substitute y and those derivatives into the left-hand side.
- Simplify and check that it equals the right-hand side for all x (an identity, not just at one point).
Example 1
Verify that y=e−3x is a solution of dx2d2y+dxdy−6y=0.
Here y′=−3e−3x and y′′=9e−3x. Substituting:
9e−3x+(−3e−3x)−6e−3x=(9−3−6)e−3x=0.
The left side is 0 for every x, so y=e−3x is a solution.
Example 2 (a solution with constants)
Verify that y=acosx+bsinx satisfies dx2d2y+y=0 for any constants a,b.
Since y′′=−acosx−bsinx=−y, we get y′′+y=0. It holds for all a,b, so this two-constant family is a solution. …
The key idea is verification of solution: substitute the given solution into the differential equation and check if it satisfies the relation.
Step 1: Differentiate y2/3−x2/3=c implicitly with respect to x:
32y−1/3dxdy−32x−1/3=0
Step 2: Multiply through by 23 and solve for dxdy: …
The given differential equation is homogeneous and can be solved by the substitution y=vx. After separating variables and integrating, the general solution is indeed y2/3−x2/3=c, so the statement is True.
The key here is recognising the structure of the equation. When you see dxdy expressed purely as a function of xy, you’re looking at a homogeneous differential equation. The standard trick — substitute y=vx — turns it into a separable equation, which you can then integrate directly.
Let’s walk through it.
- Rewrite the equation We have
dxdy=(xy)1/3.
The right-hand side depends only on the ratio y/x, confirming homogeneity.
- Substitute y=vx Then y=vx implies dxdy=v+xdxdv (by the product rule). The equation becomes
v+xdxdv=v1/3.
- Separate variables Subtract v from both sides:
xdxdv=v1/3−v.
Factor the right-hand side:
v1/3−v=v1/3(1−v2/3).
So
xdxdv=v1/3(1−v2/3).
Now separate:
v1/3(1−v2/3)dv=xdx.
- Integrate both sides The left side looks messy, but a clever substitution cleans it up. Let t=v2/3. Then v=t3/2, so dv=23t1/2dt. Also v1/3=t1/2. Substituting:
v1/3(1−v2/3)dv=t1/2(1−t)23t1/2dt=23⋅1−tdt.
The integral becomes
23∫1−tdt=∫xdx.
Integrating:
−23log∣1−t∣=log∣x∣+C.
The substitution t=v2/3 is the natural choice because the denominator has 1−v2/3. It turns the integral into a standard logarithmic form.
- Back-substitute Recall t=v2/3 and v=y/x, so t=(y/x)2/3=y2/3/x2/3. Then 1−t=1−x2/3y2/3=x2/3x2/3−y2/3. The equation becomes
−23logx2/3x2/3−y2/3=log∣x∣+C.
Use logarithm properties:
−23[log∣x2/3−y2/3∣−log∣x2/3∣]=log∣x∣+C.
But log∣x2/3∣=32log∣x∣, so …
Method: Verifying a Proposed Solution by Implicit Differentiation
To test whether a given relation solves a differential equation, differentiate the relation implicitly and check that it reproduces the equation — no need to solve from scratch.
Steps
Step 1: Differentiate the candidate relation with respect to x.
Treat y as a function of x, so every y-term picks up a factor dxdy by the chain rule.
Step 2: Solve the differentiated relation for dxdy.
Collect the dxdy term and isolate it.
Step 3: Compare with the original equation. …
Showing the 12 most recent of 86 on this concept.
- TG EAPCET 2026Set eng-2026-05-11-FN1 markMCQQ.The general solution of the differential equation (2xy+y2)dy=(x2−y2)dx is (A) x3−3x2y−y3=c (B) x3−3x2y+y3=c (C) x3−3xy2+y3=c (D) x3−3xy2−y3=c
›Reveal solutionSolution
This is a homogeneous differential equation. Substituting y=vx reduces it to a separable form, and integrating gives the general solution x3−3xy2−y3=c, which matches option (D).
The given equation is (2xy+y2)dy=(x2−y2)dx. Notice that every term is of degree 2 — 2xy, y2, x2, y2 — so the equation is homogeneous. For a homogeneous equation, the standard trick is to set y=vx, which turns the equation into one where variables separate cleanly.
- Rewrite in standard form Bring the dx term to the left:
(2xy+y2)dy−(x2−y2)dx=0
Or equivalently,
dxdy=2xy+y2x2−y2
- Substitute y=vx Then dxdy=v+xdxdv. The right-hand side becomes:
2x(vx)+(vx)2x2−(vx)2=x2(2v+v2)x2(1−v2)=2v+v21−v2
So the equation is:
v+xdxdv=2v+v21−v2
- Separate variables Subtract v from both sides:
xdxdv=2v+v21−v2−v=2v+v21−v2−v(2v+v2)
Simplify the numerator:
1−v2−2v2−v3=1−3v2−v3
So:
xdxdv=2v+v21−3v2−v3
Now separate:
1−3v2−v32v+v2dv=xdx
- Integrate both sides The left-hand side is set up for a simple substitution. Let u=1−3v2−v3. Then du=(−6v−3v2)dv=−3(2v+v2)dv. Notice that 2v+v2 appears in the numerator, so:
1−3v2−v32v+v2dv=−31udu
Integrating:
∫−31udu=∫xdx
−31log∣u∣=log∣x∣+C
Multiply by −3:
log∣u∣=−3log∣x∣−3C …
- TG EAPCET 2023Set eng-2023-05-12-FN1 markMCQQ.The general solution of dxdy+yf′(x)−f(x)f′(x)=0,y=f(x) is (A) y=f(x)+1+ce−f(x) (B) y=ce−f(x) (C) y=f(x)−1+ce−f(x) (D) y=f(x)+cef(x)
›Reveal solutionSolution
This is a first-order linear ODE disguised by the presence of f(x) and f′(x). By rewriting it in standard form and using an integrating factor ef(x), the general solution simplifies to y=f(x)−1+ce−f(x), which corresponds to option (C).
We start with the given differential equation:
dxdy+yf′(x)−f(x)f′(x)=0,y=f(x).
Concept & Intuition
The equation looks messy because of the f(x) and f′(x) terms, but notice that f′(x) appears as a coefficient of y and also multiplied by f(x). This suggests we can rearrange it into the standard linear form dxdy+P(x)y=Q(x), where P(x) and Q(x) are functions of x only. Once in that form, the method of integrating factor works cleanly. The key trick: treat f(x) as some known function (we don't need its explicit form), and f′(x) as its derivative.
Step-by-step solution
- Rewrite the equation in standard linear form Bring the term −f(x)f′(x) to the right-hand side:
dxdy+f′(x)y=f(x)f′(x).
This is now of the form dxdy+P(x)y=Q(x) with P(x)=f′(x) and Q(x)=f(x)f′(x).
- Find the integrating factor The integrating factor μ(x) is given by e∫P(x)dx. Here:
∫P(x)dx=∫f′(x)dx=f(x)+C.
We only need one integrating factor, so take μ(x)=ef(x).
- Multiply through by the integrating factor
ef(x)dxdy+ef(x)f′(x)y=ef(x)f(x)f′(x).
The left-hand side is the derivative of yef(x) with respect to x (by the product rule, since dxdef(x)=ef(x)f′(x)). So we have:
dxd(yef(x))=ef(x)f(x)f′(x).
- Integrate both sides
yef(x)=∫ef(x)f(x)f′(x)dx.
Notice that the integrand is set up for a substitution: let u=f(x), then du=f′(x)dx, so:
∫euudu.
This is a standard integral. Use integration by parts: let w=u, dv=eudu, then dw=du, v=eu. So:
∫ueudu=ueu−∫eudu=ueu−eu+C=eu(u−1)+C. …
- TG EAPCET 2021Set eng-2021-08-04-FN1 markMCQQ.The general solution of dxdy=x+sinxcosy+xcosy+sinx is (A) tan2x=2y2−cosy+C (B) tan2y=2x2−cosx+C (C) sec22y=2x2−cosx+C (D) tan2y=2x2+cosx+Cx
›Reveal solutionSolution
The given differential equation is separable after factoring. The solution is found by integrating both sides, leading to tan2y=2x2−cosx+C, which matches option (B).
The key is to notice that the right-hand side can be grouped into terms that depend only on x and terms that depend only on y. That’s the hallmark of a separable differential equation — and once you see the pattern, the integration is straightforward.
Let’s rewrite the equation:
dxdy=x+sinxcosy+xcosy+sinx
Group the terms cleverly:
dxdy=(x+sinx)+(sinxcosy+xcosy)
Factor cosy from the last two terms:
dxdy=(x+sinx)+cosy(x+sinx)
Now factor (x+sinx) out of the whole right-hand side:
dxdy=(x+sinx)(1+cosy)
This is clearly separable: the x-part is (x+sinx) and the y-part is (1+cosy).
- Separate the variables Bring all y terms to the left and x terms to the right:
1+cosydy=(x+sinx)dx
- Integrate both sides The left side uses a standard trigonometric identity. Recall:
1+cosy=2cos22y
So:
1+cosy1=2cos22y1=21sec22y
Therefore:
∫1+cosydy=21∫sec22ydy
Let u=y/2, then dy=2du, and:
21∫sec2u⋅2du=∫sec2udu=tanu+C=tan2y+C
The right side integrates easily:
- TG EAPCET 2023Set eng-2023-05-13-AN1 markMCQQ.The general solution of the differential equation (secx+tanx)dxdy+(sec2x+secxtanx)y=1 is (A) (1+sinx)y=ncosx+c (B) (1+cosx)y=xsinx+c (C) (secx+tanx)y=xsecx+c (D) (secx+tanx)y=x+c
›Reveal solutionSolution
This is a first-order linear ODE. Rewriting it in standard form and applying the integrating factor method shows that the general solution is (secx+tanx)y=x+c, which matches option (D).
The key concept is recognizing the equation as a first-order linear differential equation of the form
dxdy+P(x)y=Q(x).
The standard method is to multiply through by an integrating factor μ(x)=e∫Pdx, which makes the left side a perfect derivative. Here, the coefficients are cleverly arranged so that the integrating factor simplifies dramatically.
- Rewrite in standard form The given equation is
(secx+tanx)dxdy+(sec2x+secxtanx)y=1.
Divide through by (secx+tanx) to isolate dxdy:
dxdy+secx+tanxsec2x+secxtanxy=secx+tanx1.
- Simplify the coefficient of y Factor the numerator: sec2x+secxtanx=secx(secx+tanx). Hence
secx+tanxsec2x+secxtanx=secx.
So the ODE becomes
dxdy+(secx)y=secx+tanx1.
- Find the integrating factor
μ(x)=e∫secxdx.
A standard integral: ∫secxdx=log∣secx+tanx∣+C.
Thus
μ(x)=elog∣secx+tanx∣=secx+tanx.
(We take the positive branch for typical intervals.)
- Multiply through by μ(x)
(secx+tanx)dxdy+(secx+tanx)(secx)y=1.
Notice the left side is exactly the derivative of (secx+tanx)y because
dxd[(secx+tanx)y]=(secx+tanx)dxdy+(secxtanx+sec2x)y, …
- TG EAPCET 2026Set eng-2026-05-11-AN1 markMCQQ.The integrating factor of the linear differential equation in x given by dxdy=3x+y+21 is (A) e−3x (B) e−x (C) e−3y (D) e−y
›Reveal solutionSolution
The given equation is not linear in y, but rewriting it as dydx=3x+y+2 makes it linear in x with integrating factor e−3y, so the correct option is (C).
We are given
dxdy=3x+y+21.
At first glance, this looks like a first-order differential equation in y as a function of x. But it is not linear in y because the right-hand side is a rational function containing y in the denominator. However, we can flip the relationship: treat x as a function of y instead.
The key insight: if dxdy is given, then dydx=1/dxdy (provided the derivative is nonzero). This often turns a nonlinear equation in y into a linear equation in x.
- Rewrite the equation in terms of x(y) Since dydx=dxdy1, we have
dydx=3x+y+2.
This is now a linear first-order differential equation in x with independent variable y.
- Identify the standard linear form The standard form for a linear ODE in x is
dydx+P(y)x=Q(y).
Our equation is
dydx−3x=y+2.
So P(y)=−3 and Q(y)=y+2.
- Recall the integrating factor formula For a linear ODE dydx+P(y)x=Q(y), the integrating factor is
μ(y)=e∫P(y)dy.
Here P(y)=−3, so
μ(y)=e∫(−3)dy=e−3y.
- Interpret the result …
- TG EAPCET 2025Set eng-2025-05-02-FN1 markMCQQ.If cosxdxdy=ysinx−1, x=(2n+1)2π, n∈Z is the differential equation corresponding to the curve y=f(x) and f(0)=1 then f(x)= (A) (1−x)secx (B) (1−x)cosx (C) x+cosx (D) x+secx
›Reveal solutionSolution
This is a first-order linear ODE. Rewriting it in standard form and using an integrating factor gives f(x)=(1−x)secx, which matches option (A).
We start with the given differential equation:
cosxdxdy=ysinx−1
The goal is to find y=f(x) satisfying f(0)=1, and then match it to one of the options.
Concept and Intuition
The equation is linear in y but not yet in standard form. The standard form for a first-order linear ODE is:
dxdy+P(x)y=Q(x)
Once in this form, we multiply through by an integrating factor μ(x)=e∫P(x)dx, which lets us write the left-hand side as the derivative of μ(x)y. Then we integrate both sides.
Here, dividing by cosx will give us P(x)=−tanx and Q(x)=−secx. The integrating factor simplifies nicely because ∫tanxdx=−log∣cosx∣, so μ(x)=secx.
Step-by-step solution
- Rewrite in standard form Divide both sides by cosx (valid since x=(2n+1)2π):
dxdy=ytanx−secx
Bring the y term to the left:
dxdy−(tanx)y=−secx
So P(x)=−tanx and Q(x)=−secx.
- Find the integrating factor
μ(x)=e∫P(x)dx=e∫−tanxdx
Since ∫tanxdx=−log∣cosx∣, we have:
∫−tanxdx=log∣cosx∣
Hence:
μ(x)=elog∣cosx∣=∣cosx∣
For the domain (where cosx>0 near x=0), we can take μ(x)=cosx. But it's more standard to use secx as the integrating factor when we multiply through — let's check.
Actually, careful: The standard formula is μ=e∫Pdx. With P=−tanx, we get μ=elog(cosx)=cosx (taking positive branch near 0). So the integrating factor is cosx.
- Multiply the ODE by μ(x)=cosx Original ODE in standard form:
dxdy−(tanx)y=−secx
Multiply by cosx:
cosxdxdy−ysinx=−1
Notice the left side is exactly dxd(ycosx) because:
- TG EAPCET 2022Set eng-2022-07-20-AN1 markMCQQ.If l and m are respectively the order and the degree of the differential equation f(x)y′′+g(x)y′=x4y whose general solution is y=ax2+blogx, then f(m)+g(m)= (A) 2l (B) l (C) 3m (D) 1+m
›Reveal solutionSolution
The key idea is to find the differential equation from its given general solution, then identify its order l and degree m, and finally evaluate f(m)+g(m) — the answer is l.
We are told that the general solution of the differential equation
f(x)y′′+g(x)y′=x4y
is y=ax2+blogx, where a and b are arbitrary constants. The functions f(x) and g(x) are not given explicitly — they are to be determined from the fact that this y satisfies the equation for all a,b.
The problem asks for f(m)+g(m), where l is the order and m is the degree of this differential equation. So we first need to find the differential equation itself.
- Find the derivatives of the given solution.
y=ax2+blogx
Differentiate:
y′=2ax+xb
Differentiate again:
y′′=2a−x2b
-
Eliminate the arbitrary constants a and b.
We have three equations: y, y′, y′′ in terms of a and b. We need one equation relating y, y′, y′′ and x alone — that is the differential equation.
From y′′=2a−x2b, we can solve for a and b in terms of y′′ and something else. But a cleaner way:
From y′=2ax+xb, multiply by x:
xy′=2ax2+b
From y=ax2+blogx, we have ax2=y−blogx. Substitute into xy′:
xy′=2(y−blogx)+b=2y−2blogx+b
This still has b. Instead, let's use y′′ directly.
From y′′=2a−x2b, multiply by x2:
x2y′′=2ax2−b
But 2ax2=2(y−blogx) from y=ax2+blogx. So:
x2y′′=2y−2blogx−b
This still contains b. We need another relation to eliminate b.
From y′=2ax+xb, multiply by x:
xy′=2ax2+b
And 2ax2=2(y−blogx). So:
xy′=2y−2blogx+b
Now subtract the x2y′′ equation from this? Let's do it systematically.
We have:
xy′=2y−2blogx+b(1)
x2y′′=2y−2blogx−b(2)
Subtract (2) from (1):
xy′−x2y′′=(2y−2blogx+b)−(2y−2blogx−b)=2b
So b=21(xy′−x2y′′).
Now add (1) and (2):
xy′+x2y′′=(2y−2blogx+b)+(2y−2blogx−b)=4y−4blogx
Substitute b:
xy′+x2y′′=4y−4(21(xy′−x2y′′))logx
xy′+x2y′′=4y−2(xy′−x2y′′)logx
Bring terms together:
xy′+x2y′′+2(xy′−x2y′′)logx=4y
Factor:
- TG EAPCET 2025Set eng-2025-05-04-FN1 markMCQQ.Consider all functions given in List-1 in the interval [1,3]. The List-2 has the values of ‘c’ obtained by applying Lagrange’s mean value theorem on the functions of List-1. Match the functions and values of ‘c’. (A) A – II, B – V, C – IV, D – III (B) A – IV, B – III, C – II, D – V (C) A – II, B – I, C – IV, D – III (D) A – IV, B – V, C – II, D – I
›Reveal solutionSolution
This is a List-I → List-II matching question on Lagrange's Mean Value Theorem over [1,3]; the official key pairs them as A–IV, B–III, C–II, D–V — option (B).
For each function f in List-I, Lagrange's Mean Value Theorem (LMVT) guarantees a point c∈(1,3) with
f′(c)=3−1f(3)−f(1)=2f(3)−f(1),
and the value of c so obtained is the List-II entry to be matched. For each function one forms this equation, solves f′(c)=21(f(3)−f(1)), and keeps the root lying in (1,3). …
- TG EAPCET 2024Set eng-2024-05-10-AN1 markMCQQ.If y=sinx+Acosx is the general solution of dxdy+f(x)y=secx, then an integrating factor of the differential equation is (A) secx (B) tanx (C) cosx (D) sinx
›Reveal solutionSolution
The given general solution is y=sinx+Acosx. Differentiating and substituting into the differential equation reveals f(x)=tanx, so the integrating factor is secx, which is option (A).
We are told that y=sinx+Acosx (where A is an arbitrary constant) is the general solution of
dxdy+f(x)y=secx.
Our goal is to find the integrating factor (I.F.) of this linear first-order ODE. The standard form is y′+P(x)y=Q(x), and the integrating factor is μ(x)=e∫P(x)dx. Here P(x)=f(x).
The key insight: If we already know the general solution, we can work backwards to find f(x) by differentiating the solution and plugging it into the equation. Then we compute the integrating factor directly.
-
Differentiate the given general solution
y=sinx+Acosx
dxdy=cosx−Asinx
-
Substitute into the differential equation
The equation is dxdy+f(x)y=secx.
So:
(cosx−Asinx)+f(x)(sinx+Acosx)=secx
- Group terms involving A and those without A Expand:
cosx−Asinx+f(x)sinx+Af(x)cosx=secx
Group constant (in A) terms: cosx+f(x)sinx
Group A terms: A(−sinx+f(x)cosx)
Since this must hold for all A (the solution is general), the coefficient of A must be zero. That gives:
−sinx+f(x)cosx=0⇒f(x)cosx=sinx⇒f(x)=tanx
- Verify the constant part With f(x)=tanx, the constant part becomes: cosx+tanx⋅sinx=cosx+cosxsin2x=cosxcos2x+sin2x=cosx1=secx …
-
- TG EAPCET 2025Set eng-2025-05-04-AN1 markMCQQ.Consider all functions given in List-I in the interval [1,3]. The List-2 has the values of ‘c’ obtained by applying Lagrange’s mean value theorem on the functions of List-1. Match the functions and values of ‘c’. (A) A – II, B – V, C – IV, D – III (B) A – II, B – I, C – IV, D – III (C) A – IV, B – V, C – II, D – I (D) A – IV, B – III, C – II, D – V
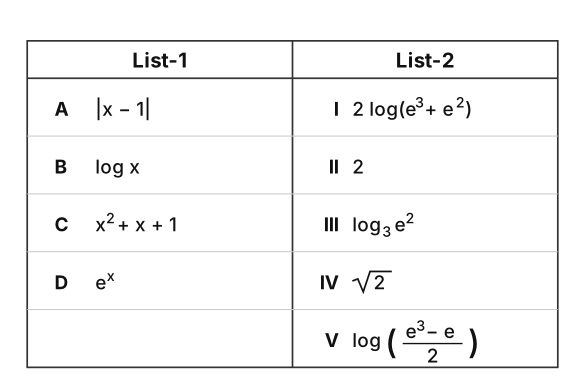
›Reveal solutionSolution
Apply f′(c)=2f(3)−f(1) to each function. You get c=2 (any c works for ∣x−1∣), c=log3e2, c=2 and c=log2e3−e — i.e. A–IV, B–III, C–II, D–V, option (D).
The concept first
Lagrange's Mean Value Theorem says something beautifully physical: if you travel from x=1 to x=3 along a smooth curve, then at some instant your instantaneous rate of change equals your average rate of change. Formally, if f is continuous on [a,b] and differentiable on (a,b), there exists c∈(a,b) with
f′(c)=b−af(b)−f(a).
So the entire job in each row is: compute the chord slope on the right, set the derivative equal to it, and solve for c.
One subtlety worth noticing: ∣x−1∣ is famously not differentiable at x=1 — but the kink is at the endpoint of [1,3], and the theorem only needs differentiability on the open interval (1,3). Inside, x>1 so ∣x−1∣=x−1, perfectly smooth.
Step-by-step
- A: f(x)=∣x−1∣ on [1,3]. Here f(x)=x−1, f(1)=0, f(3)=2.
chord slope=22−0=1,f′(x)=1 ∀x∈(1,3).
The equation f′(c)=1 is satisfied by every c in (1,3). The only List-2 value lying in (1,3) that is not already claimed by another (uniquely determined) function is 2≈1.414. → A – IV.
2. B: f(x)=logx (natural log) on [1,3]. f(1)=0, f(3)=log3.
f′(c)=c1=2log3−0=2log3 ⟹ c=log32. …
- TG EAPCET 2026Set eng-2026-05-09-FN1 markMCQQ.If dxdy−x2+b2xy=−2x(x2+b), y(0)=12, y(1)=10, then sum of all possible values of b is (A) 1 (B) 4 (C) −3 (D) −1
›Reveal solutionSolution
This is a first-order linear ODE solved via an integrating factor; the two boundary conditions force a specific value of the parameter b, and the sum of all possible b values is −3.
We are given the differential equation
dxdy−x2+b2xy=−2x(x2+b),
with conditions y(0)=12 and y(1)=10. The parameter b is unknown, and we must find all possible b that allow both conditions to hold, then sum them.
Concept and intuition
This is a first-order linear ODE of the form
dxdy+P(x)y=Q(x).
The standard method: multiply by an integrating factor μ(x)=e∫P(x)dx to make the left side a perfect derivative. Here P(x)=−x2+b2x, so the integrating factor will simplify nicely because the numerator is the derivative of the denominator. The right-hand side is a polynomial times (x2+b), so after multiplication we’ll integrate easily.
The twist: we have two boundary conditions for a first-order ODE — that usually overdetermines the system. The parameter b must adjust so that both conditions are consistent. We’ll solve the ODE in terms of b and a constant C, then impose y(0)=12 and y(1)=10 to get equations that determine b.
Step-by-step solution
1. Identify P(x) and compute the integrating factor.
Rewrite the ODE as
dxdy+(−x2+b2x)y=−2x(x2+b).
So P(x)=−x2+b2x. Then
∫P(x)dx=−∫x2+b2xdx=−log∣x2+b∣+constant.
Thus the integrating factor is
μ(x)=e∫Pdx=e−log∣x2+b∣=x2+b1.
(We can drop absolute values since b will be chosen so that x2+b>0 on the interval containing 0 and 1, or we treat it as a formal algebraic factor.)
2. Multiply the ODE by μ(x).
x2+b1dxdy−(x2+b)22xy=−2x.
Notice the left side is exactly
dxd(x2+by).
Check: derivative of x2+by is x2+by′−(x2+b)22xy. Yes.
So we have
dxd(x2+by)=−2x.
3. Integrate both sides.
x2+by=∫(−2x)dx=−x2+C,
where C is an arbitrary constant.
Thus
y(x)=(x2+b)(−x2+C).
4. Apply the first condition y(0)=12.
At x=0:
y(0)=(0+b)(0+C)=bC=12⇒C=b12.
5. Apply the second condition y(1)=10.
At x=1:
y(1)=(1+b)(−1+C)=10.
Substitute C=b12:
(1+b)(−1+b12)=10.
6. Solve for b.
Simplify the left side:
- TG EAPCET 2021Set eng-2021-08-05-FN1 markMCQQ.If x=2+22/3+21/3, then x3−6x2+6x= (A) 3 (B) 2 (C) 1 (D) 0
›Reveal solutionSolution
The key idea is to rewrite the given expression as a cubic equation by setting t=21/3, then substituting x=t2+t+2 and simplifying to find x3−6x2+6x=2.
We are given x=2+22/3+21/3. The expression x3−6x2+6x looks like it might simplify to a constant — a common trick in such problems. The direct approach of cubing x would be messy, so we look for a smarter algebraic structure.
Notice that 21/3 and 22/3 are related: if we let t=21/3, then t3=2 and t2=22/3. So x becomes x=t2+t+2. The problem now reduces to working with t, where t3=2 is a clean relation.
-
Set up the substitution.
Let t=21/3. Then t3=2, and x=t2+t+2.
-
Express x in terms of t and find a relation.
We have x−2=t2+t.
Square both sides? That would give t4+2t3+t2, but t4=t⋅t3=2t, so it might work. But a more elegant path is to notice that t satisfies t3−2=0, and x is a symmetric polynomial in t. We can compute x3−6x2+6x directly by substituting x=t2+t+2 and simplifying using t3=2.
-
Compute x2 and x3 in terms of t.
First, x2=(t2+t+2)2
=t4+t2+4+2t3+4t2+4t (expand carefully: (a+b+c)2=a2+b2+c2+2ab+2bc+2ca)
=t4+2t3+(t2+4t2)+4t+4
=t4+2t3+5t2+4t+4.
Now t4=t⋅t3=2t, and t3=2, so:
x2=2t+2(2)+5t2+4t+4
=2t+4+5t2+4t+4
=5t2+6t+8.
Next, x3=x⋅x2=(t2+t+2)(5t2+6t+8).
Multiply term by term:
t2(5t2+6t+8)=5t4+6t3+8t2
t(5t2+6t+8)=5t3+6t2+8t
2(5t2+6t+8)=10t2+12t+16
Summing: x3=5t4+(6t3+5t3)+(8t2+6t2+10t2)+(8t+12t)+16
=5t4+11t3+24t2+20t+16.
Replace t4=2t and t3=2:
x3=5(2t)+11(2)+24t2+20t+16
=10t+22+24t2+20t+16
=24t2+30t+38.
-
Now form x3−6x2+6x.
We have:
x3=24t2+30t+38
6x2=6(5t2+6t+8)=30t2+36t+48
6x=6(t2+t+2)=6t2+6t+12 …
-
🎓Unlock everything free for 14 days
- ✓Full step-by-step solutions
- ✓Concept-first explanations
- ✓Methods, shortcuts & mistakes
- ✓PYQ mapping + timed mock tests
Full access for 14 days. No credit card required.