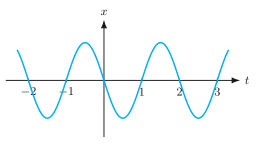
Q.Figure 2.13 gives the x-t plot of a particle executing one-dimensional simple harmonic motion. (You will learn about this motion in more detail in Chapter 13). Give the signs of position, velocity and acceleration variables of the particle at t=0.3 s, 1.2 s, −1.2 s.
Simple Harmonic Motion: The Natural Rhythm of Things
Imagine a ball placed at the bottom of a perfectly smooth, U-shaped bowl. If you give it a gentle push, what happens? It rolls up one side, slows down, stops for an instant, then rolls back down, past the bottom, up the other side, stops, and returns. Left alone, it keeps doing this — back and forth, back and forth — in a steady, repeating rhythm.
That rhythm is the heart of Simple Harmonic Motion (SHM). It's the most fundamental kind of oscillatory (back-and-forth) motion in physics.
The Intuition: A Restoring Force That Fights Displacement
The key idea is this: the further you push the object from its resting (equilibrium) position, the stronger the force that tries to pull it back.
In the bowl, when the ball is at the bottom (equilibrium), gravity pulls straight down, and the bowl pushes straight up — no sideways force. But when you push the ball up the side, gravity now has a component that pulls it down the slope. The higher up the side you push it, the steeper the slope, and the stronger that pull-back force becomes.
This is a restoring force — it always points toward equilibrium. And crucially, in SHM, this restoring force is directly proportional to the displacement from equilibrium. Double the displacement, double the restoring force.
F=−kx
F is the restoring force.
x is the displacement from equilibrium.
k is a positive constant (the "stiffness" of the system).
The minus sign is crucial: it tells you the force is opposite to the displacement.
The Precise Statement
Simple Harmonic Motion is the motion of an object where the restoring force is directly proportional to the displacement from equilibrium and acts in the opposite direction.
That's it. That single condition — F=−kx — is the entire definition. Everything else (the sine waves, the formulas for period and frequency) follows mathematically from this one law.
What Does This Motion Look Like?
If you track the ball's position over time, you get a beautiful, smooth wave — a sine wave (or cosine wave). It's the same shape as the shadow of a spinning wheel cast on a wall.
The motion has three key descriptors:
Amplitude (A): The maximum displacement from equilibrium. How far you initially pushed the ball up the side of the bowl.
Period (T): The time it takes to complete one full back-and-forth cycle (e.g., from the leftmost point, back to the leftmost point).
Frequency (f): How many cycles happen per second. f=1/T.
Note
A remarkable fact: for a given system (fixed k and fixed mass m), the period and frequency do not depend on the amplitude. A big push and a tiny push take exactly the same time to complete one cycle. This is called isochronism — and it's why pendulums were used to keep time in clocks.
The Mathematical Description (Derived from F=−kx)
Using Newton's second law (F=ma) and the definition of acceleration (a=dt2d2x), the condition F=−kx becomes:
mdt2d2x=−kx
This is a differential equation. Its solution — the position as a function of time — is:
x(t)=Acos(ωt+ϕ)
Where:
ω=mk is the angular frequency (radians per second). It tells you how fast the oscillation is.
ϕ is the phase constant (determines where in the cycle you start measuring time). …
Model the curve as x(t)=−Asin(πt) (period 2s, amplitude A>0, crossing zero at every integer t and dipping negative just after t=0). Then v(t)=x˙=−Aπcos(πt) and a(t)=x¨=−π2x(t) — for SHM the acceleration is always directed opposite to the displacement, back towards the centre x=0.
At t=0.3s: the phase is π(0.3)=0.3π rad =54∘, which lies between 0∘ and 90∘ (the particle is in its first swing away from the origin, not yet at the far end). Here sin(0.3π)>0, so x=−Asin(0.3π)<0. Also cos(0.3π)>0, so v=−Aπcos(0.3π)<0 (still moving away from the origin, in the negative direction). Since x<0, a=−π2x>0 (accelerating back towards x=0).
At t=1.2s: the phase is 1.2π rad =216∘, which lies between 180∘ and 270∘ (third quadrant), where both sin and cos are negative. So x=−Asin(1.2π)=−A(negative)>0, v=−Aπcos(1.2π)=−Aπ(negative)>0, and since x>0, a=−π2x<0. …
The graph is x(t)=−Asin(πt) with amplitude A>0 and period 2s (it crosses zero at every integer t and dips negative just after t=0). Differentiating gives velocity and acceleration, and for SHM the acceleration always points opposite to the displacement. Evaluating the signs at the three instants gives (−,−,+), (+,+,−) and (−,+,+).
Setting up the motion
The curve is zero at t=0 and negative just after, so write
Concept: Reading Signs Directly Off the Sketched Curve
Method: Direct Curve-Reading by Region (slope and concavity, no explicit trigonometric formula)
Rather than writing x(t)=−Asin(πt) and differentiating it twice, this method reads every sign directly off the described shape of the curve — using only two general facts valid for any smooth, periodic up-down curve: (i) inside any trough (a stretch between two zero-crossings that dips below the axis), the curve is concave up everywhere, and inside any crest, concave down everywhere;
(ii) within a trough or crest, the velocity sign flips exactly once, at the extremum itself — negative (falling) before it, positive (rising) after it, for a trough (and the reverse for a crest).
Setting up the regions from the description
Trough (dips below axis): between t=0 and t=1 (bottom near t=0.5), and again between t=−2 and t=−1 (bottom near t=−1.5), by the stated period of 2s.
Crest (rises above axis): between t=−1 and t=0 (top near t=−0.5), and between t=1 and t=2 (top near t=1.5).
Evaluating each instant
t=0.3s lies inside the trough (0,1), before its bottom at t=0.5: position is below the axis (x<0); the curve is still descending toward the bottom, so velocity is still falling (v<0); concavity is upward throughout this entire trough (a>0).
→ x<0,v<0,a>0
t=1.2s lies inside the crest (1,2), before its top at t=1.5: position is above the axis (x>0); the curve is still rising toward the top, so velocity is still rising (v>0); concavity is downward throughout this entire crest (a<0).