Physics · Ch 6 — System of Particles and Rotational Motion
Vector Product of Two Vectors
Vector Product of Two Vectors
Vector Product of Two Vectors
When two vectors are multiplied in a way that the result is a vector, the operation is called a vector product or cross product. Unlike scalar multiplication, which gives a number, the vector product gives a new vector whose magnitude and direction both carry physical meaning. In rotational motion, this operation appears naturally — torque, angular momentum, and angular velocity are all defined through vector products.
The vector product of two vectors and is written as and read as "a cross b". The result is a third vector whose magnitude is
where , , and is the smaller angle between and , measured from to ().
The direction of is perpendicular to the plane containing and . But perpendicular to a plane gives two opposite possibilities — up or down. Which one do we choose? The answer comes from the right‑hand rule.
Right‑hand rule for direction
Stretch your right hand so that your fingers curl from toward through the smaller angle . Your extended thumb then points in the direction of .
Because the direction depends on the order of the vectors, the vector product is not commutative. Swapping the order reverses the direction:
This anti‑commutative property is one of the most important features of the cross product.
Common mistake
Many students assume because scalar multiplication is commutative. That is false for vector products. The magnitudes are equal, but the directions are opposite.
Geometrical interpretation
The magnitude has a simple geometric meaning. If and are drawn from a common origin, they form two adjacent sides of a parallelogram. The area of that parallelogram is
So the magnitude of the cross product equals the area of the parallelogram spanned by the two vectors. If the vectors are parallel ( or ), the area is zero and . If they are perpendicular (), the magnitude is simply .
Zero vector product
if and only if and are parallel (or one of them is the zero vector). This is because only when or .
Vector product in terms of components
To compute cross products algebraically, we express vectors in terms of their components along the coordinate axes. Let , , be the unit vectors along the , , axes respectively. These unit vectors are mutually perpendicular and follow the right‑hand rule: , , .
The cross products among the unit vectors are:
| Product | Result |
|---|---|
Notice the cyclic pattern: gives a positive result; going against the cycle gives a negative result.
Now write two vectors in component form:
Their vector product is
Using the distributive property (which holds for vector products) and the unit‑vector results above, we expand term by term. Every product of a unit vector with itself vanishes. The cross terms give:
Substituting the unit‑vector results:
Grouping the components of , , :
This is the component form of the vector product. It is often written compactly as a determinant:
Expanding this determinant gives exactly the same expression. The determinant form is the easiest way to remember and compute cross products.
How to use the determinant
Expand along the first row:
The minus sign on the term is crucial — it comes from the cofactor expansion.
Properties of the vector product
The textbook lists several important properties. Each one is proved directly from the definition or from the component form.
›Proof
Property 1: Anti‑commutativity
From the magnitude definition, and , so the magnitudes are equal. The direction of is given by the right‑hand rule curling from to ; curling from to reverses the thumb direction. Hence points opposite to , giving the negative sign.
In components, swapping the rows of the determinant changes its sign, confirming the result.
›Proof
Property 2: Distributive law
Write all vectors in component form. The left side becomes
Expanding the determinant, each term splits into a sum. For example, the component is , which is exactly the sum of the components of and . The same holds for the and components. Hence the distributive law holds.
›Proof
Property 3: Scalar multiplication
, where is a scalar.
In the determinant, multiplying any row by multiplies the entire determinant by . So has the first row of the determinant scaled by , giving times the original determinant. Similarly, scaling the second row gives .
›Proof
Property 4: Parallel vectors give zero
If and are parallel (or one is zero), then .
For parallel vectors, or , so and the magnitude is zero. In components, if , then the rows of the determinant are proportional, making the determinant zero.
›Proof
Property 5: Self‑product is zero
This is a special case of Property 4 with . The two rows of the determinant are identical, so the determinant vanishes.
›Proof
Property 6: Magnitude and dot product relation
Start with . Since , we have
But , so
This identity connects the cross product and dot product magnitudes.
›Proof
Property 7: Scalar triple product (cyclic property)
…
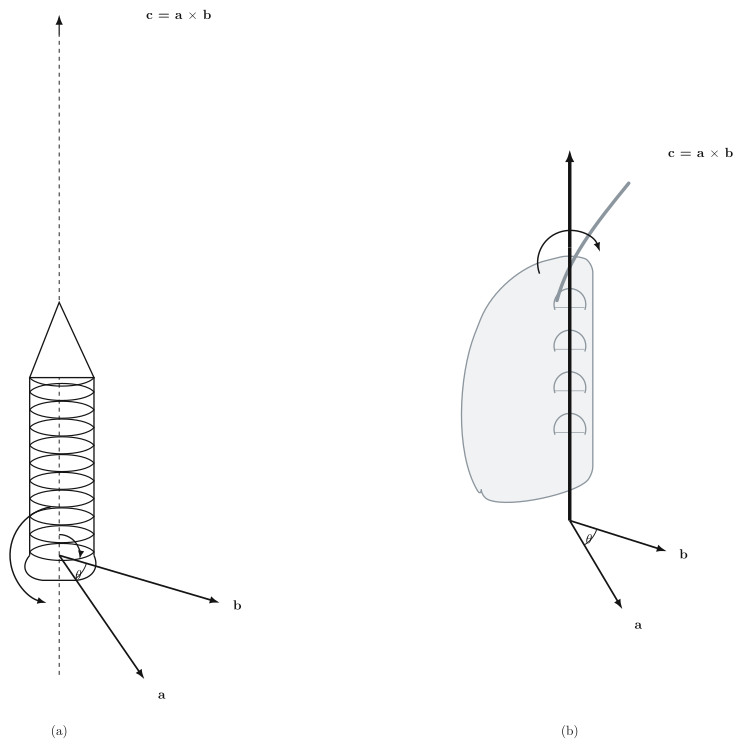
Drawn by us to help you understand the concept clearly, and verified to make sure it's accurate. For exams, practice from your NCERT textbook's own diagram.
Figure 6.15 in the NCERT textbook is a pair of visual mnemonics for the vector product (also called the cross product). The figure does not plot data or show a graph; it shows two different ways to determine the direction of the vector when you already know the two vectors and and the angle between them.
Panel (a) uses a right-handed screw. Imagine a screw placed at the common tail of and , with its axis perpendicular to the plane containing and . If you rotate the screw from toward through the smaller angle , the direction in which the screw advances (moves forward) is the direction of . The figure shows the screw’s head with a curved arrow indicating the rotation, and the screw’s tip moving upward along .
Panel (b) uses your right hand. Curl the fingers of your right hand from toward through the angle (the same smaller angle). Your extended thumb then points in the direction of . The figure shows a stylised right hand with the curled fingers and the thumb sticking out along , while and are drawn near the wrist.
Both rules give the same result: the cross product is perpendicular to the plane containing and , and its sense is given by the right-hand rule. The magnitude of is , which is the area of the parallelogram spanned by and .
where is the smaller angle between and (). The direction of is given by the right-hand rule (or the right-handed screw rule).
The cross product is not commutative: . Swapping the order reverses the direction of . The right-hand rule must be applied with the first vector rotated toward the second — the screw turns from to , not the other way. …