Mathematics · Ch 8 — Differentiation
Derivatives of Standard Inverse Trigonometric Functions
Derivatives of Standard Inverse Trigonometric Functions
This section derives the standard derivative of each inverse trigonometric function, by writing as , differentiating implicitly with respect to , and converting the result back into using a Pythagorean identity — with the sign fixed by which quadrant the principal-branch angle can lie in.
1. , , . Then . Differentiating w.r.t. : . Since , lies in the 1st or 4th quadrant, where , so the positive sign is taken: . By the inverse-function theorem, , for .
2. , : left as an exercise for the student to prove by the same method (writing ); the standard result is .
3. , , . Then . Differentiating w.r.t. : . So .
4. , : left as homework by the same method (writing , ); the standard result is .
5. , , , . Then . Differentiating: . The sign is fixed by noting and are both positive in Quadrant I and both negative in Quadrant II, so their product is positive throughout this branch; matching that against (Quadrant I, giving ) and (Quadrant II, giving ) shows when and when . Reciprocating: for , and for .
Note 1. A function is increasing where its derivative is positive and decreasing where its derivative is negative. Note 2. The derivative of is always positive, because the graph of is always increasing (on each piece of its domain).
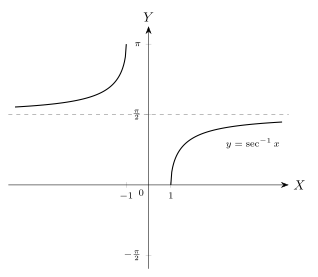
Drawn by us to help you understand the concept clearly, and verified to make sure it's accurate. For exams, practice from your textbook's own diagram.
What this figure shows. A diagram of the coordinate plane's four quadrants used to justify the sign taken for sec y . tan y while deriving the derivative of sec^{-1} x: it marks that y (the angle whose secant is x) lies only in the first or second quadrant under the principal branch 0 <= y <= pi, y not equal to pi/2, and shows that sec y and tan y are both positive together in the first quadrant and both negative together in the second quadrant, so their product sec y tan y is always positive there — which is what fixes the sign of dx/dy …
…