Physics · Ch 7 — System of Particles and Rotational Motion
Kinematics of Rotational Motion About a Fixed Axis
Kinematics of Rotational Motion About a Fixed Axis
Opening the Section: From Linear to Rotational Kinematics
You already know how to describe motion along a straight line using displacement, velocity, and acceleration — all linked by the equations of motion. Rotational motion about a fixed axis follows the same logical structure, but with angular quantities replacing their linear counterparts. The key insight is that every linear kinematic equation has a direct rotational analogue, provided the axis stays fixed in space.
For a rigid body rotating about a fixed axis, every particle moves in a circle centred on that axis. The angular displacement , angular velocity , and angular acceleration are the same for all particles of the body — they are global quantities. This uniformity is what makes the kinematics of rotation so elegantly parallel to linear kinematics.
The Rotational Kinematic Variables
Let the axis of rotation be the -axis. At time , let the angular position be . The angular velocity is the rate of change of angular displacement:
Angular acceleration is the rate of change of angular velocity:
These definitions are exact analogues of and . The direction of is given by the right-hand rule (along the axis of rotation), and points in the same direction as if the rotation is speeding up, opposite if slowing down.
The equations we are about to derive assume constant angular acceleration (). If varies with time, you must integrate the definitions directly — the constant-acceleration formulas do not apply.
Deriving the Equations of Rotational Motion (Constant )
When is constant, we can integrate the definitions exactly as we do for linear motion. Let be the angular velocity at , and the initial angular position.
Step 1: Angular velocity as a function of time
From , integrate:
Since is constant:
This is the rotational analogue of .
Step 2: Angular displacement as a function of time
From , substitute :
Integrate:
This is the rotational analogue of .
Step 3: Angular velocity as a function of angular displacement
Eliminate between the first two equations. From , we have . Substitute into :
Multiply through by :
Expand the right side: .
Thus:
This is the rotational analogue of .
The Three Equations of Rotational Kinematics (Constant )
Relating Rotational and Linear Quantities
For a particle at a perpendicular distance from the axis of rotation, its linear speed is related to the angular speed by:
This follows because the particle travels an arc length in time , so .
The tangential acceleration (the component of linear acceleration along the direction of motion) is:
And the centripetal (radial) acceleration is:
The total linear acceleration of the particle is the vector sum of these two perpendicular components:
…
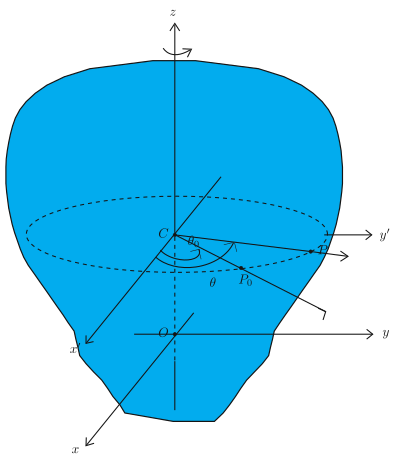
Drawn by us to help you understand the concept clearly, and verified to make sure it's accurate. For exams, practice from your textbook's own diagram.
The figure shows a rigid body of arbitrary shape rotating about a fixed vertical -axis. The axis passes through a fixed origin . Two sets of axes are drawn: the stationary axes , , (with vertical), and the rotating axes , , (the -axis is common to both). The and axes are fixed in the body and rotate with it.
A point is marked on the body — it is the centre of a horizontal dashed circle. This dashed circle lies in a plane perpendicular to the -axis. The point is the foot of the perpendicular from the body's centre of mass onto the rotation axis, but more importantly, it is the centre of the circular path traced by any particle of the body that lies in that horizontal plane.
A specific particle of the rigid body is shown. Its initial position is labelled , and its current position is . The angular position of the particle (and hence of the whole rigid body) is measured by the angle that the line makes with the rotating -axis. The initial angular position is , the angle that makes with the same -axis.
The key physical idea is this: for a rigid body rotating about a fixed axis, every particle moves in a circle centred on the axis. The entire body's orientation is completely specified by a single angular coordinate — the angle through which the body has rotated from some reference orientation. This is the rotational analogue of the linear coordinate for translational motion.
The textbook develops the kinematic equations for rotational motion using this figure. The angular displacement is . The average angular velocity is , and the instantaneous angular velocity is . Similarly, angular acceleration is .
For constant angular acceleration , the equations of rotational motion are:
These are direct analogues of the linear equations , , and , with replacing , replacing , and replacing . …